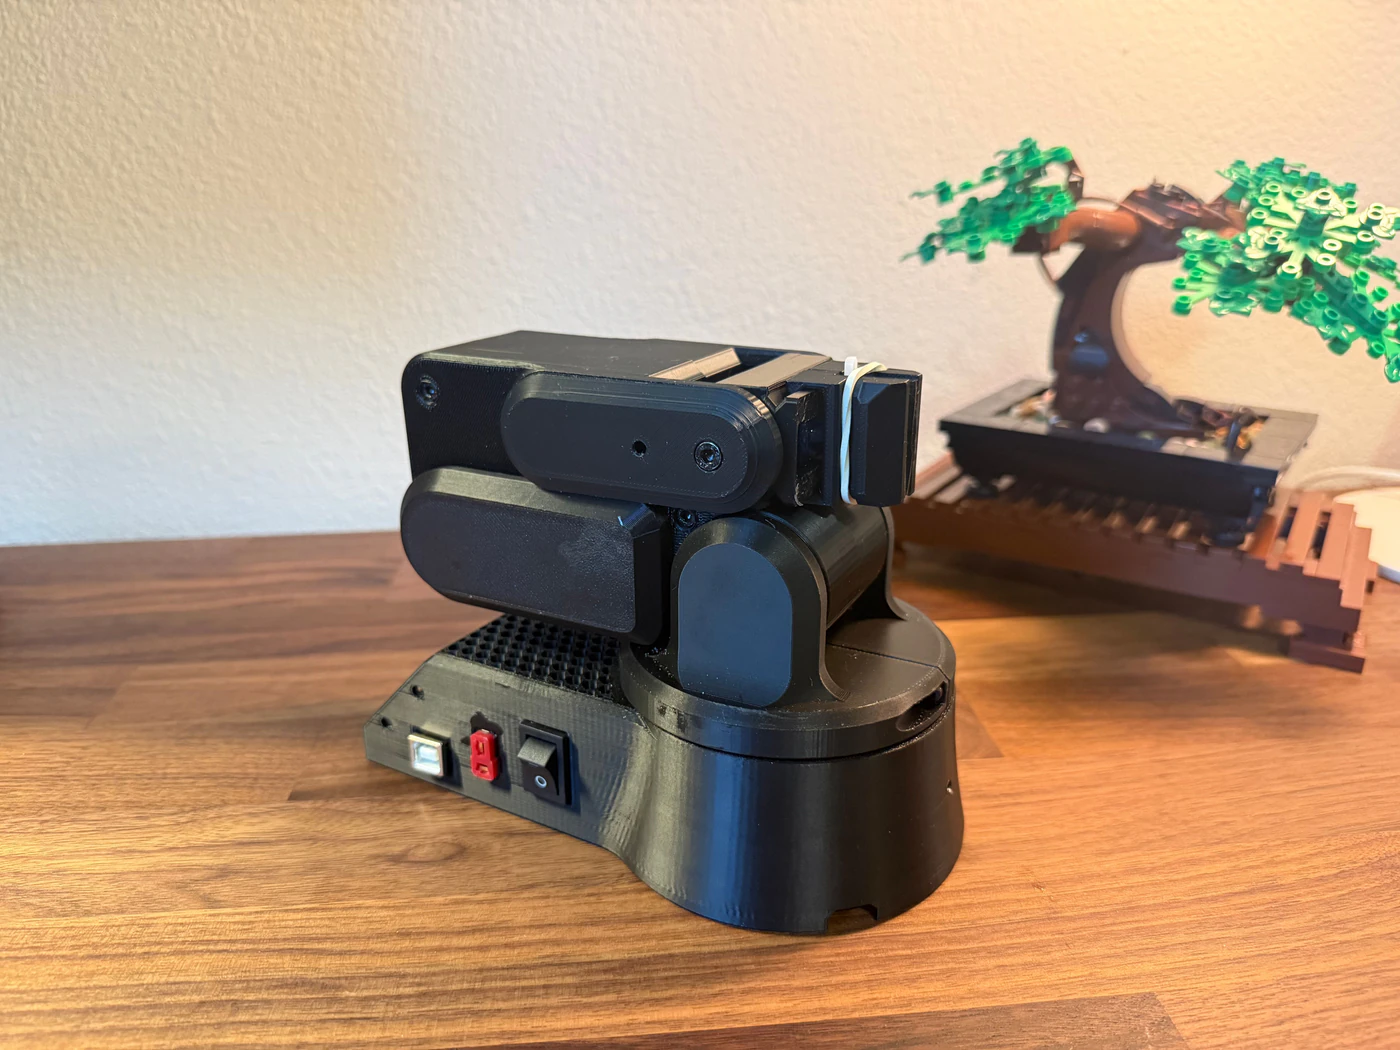
A 4-axis arm designed in SolidWorks with fully custom 3D-printed parts, driven in real time by a smaller copy of itself: move the small arm, and the big one follows.
01
Move the small arm, the big one follows
Designed in SolidWorks with every structural part custom and 3D printed.
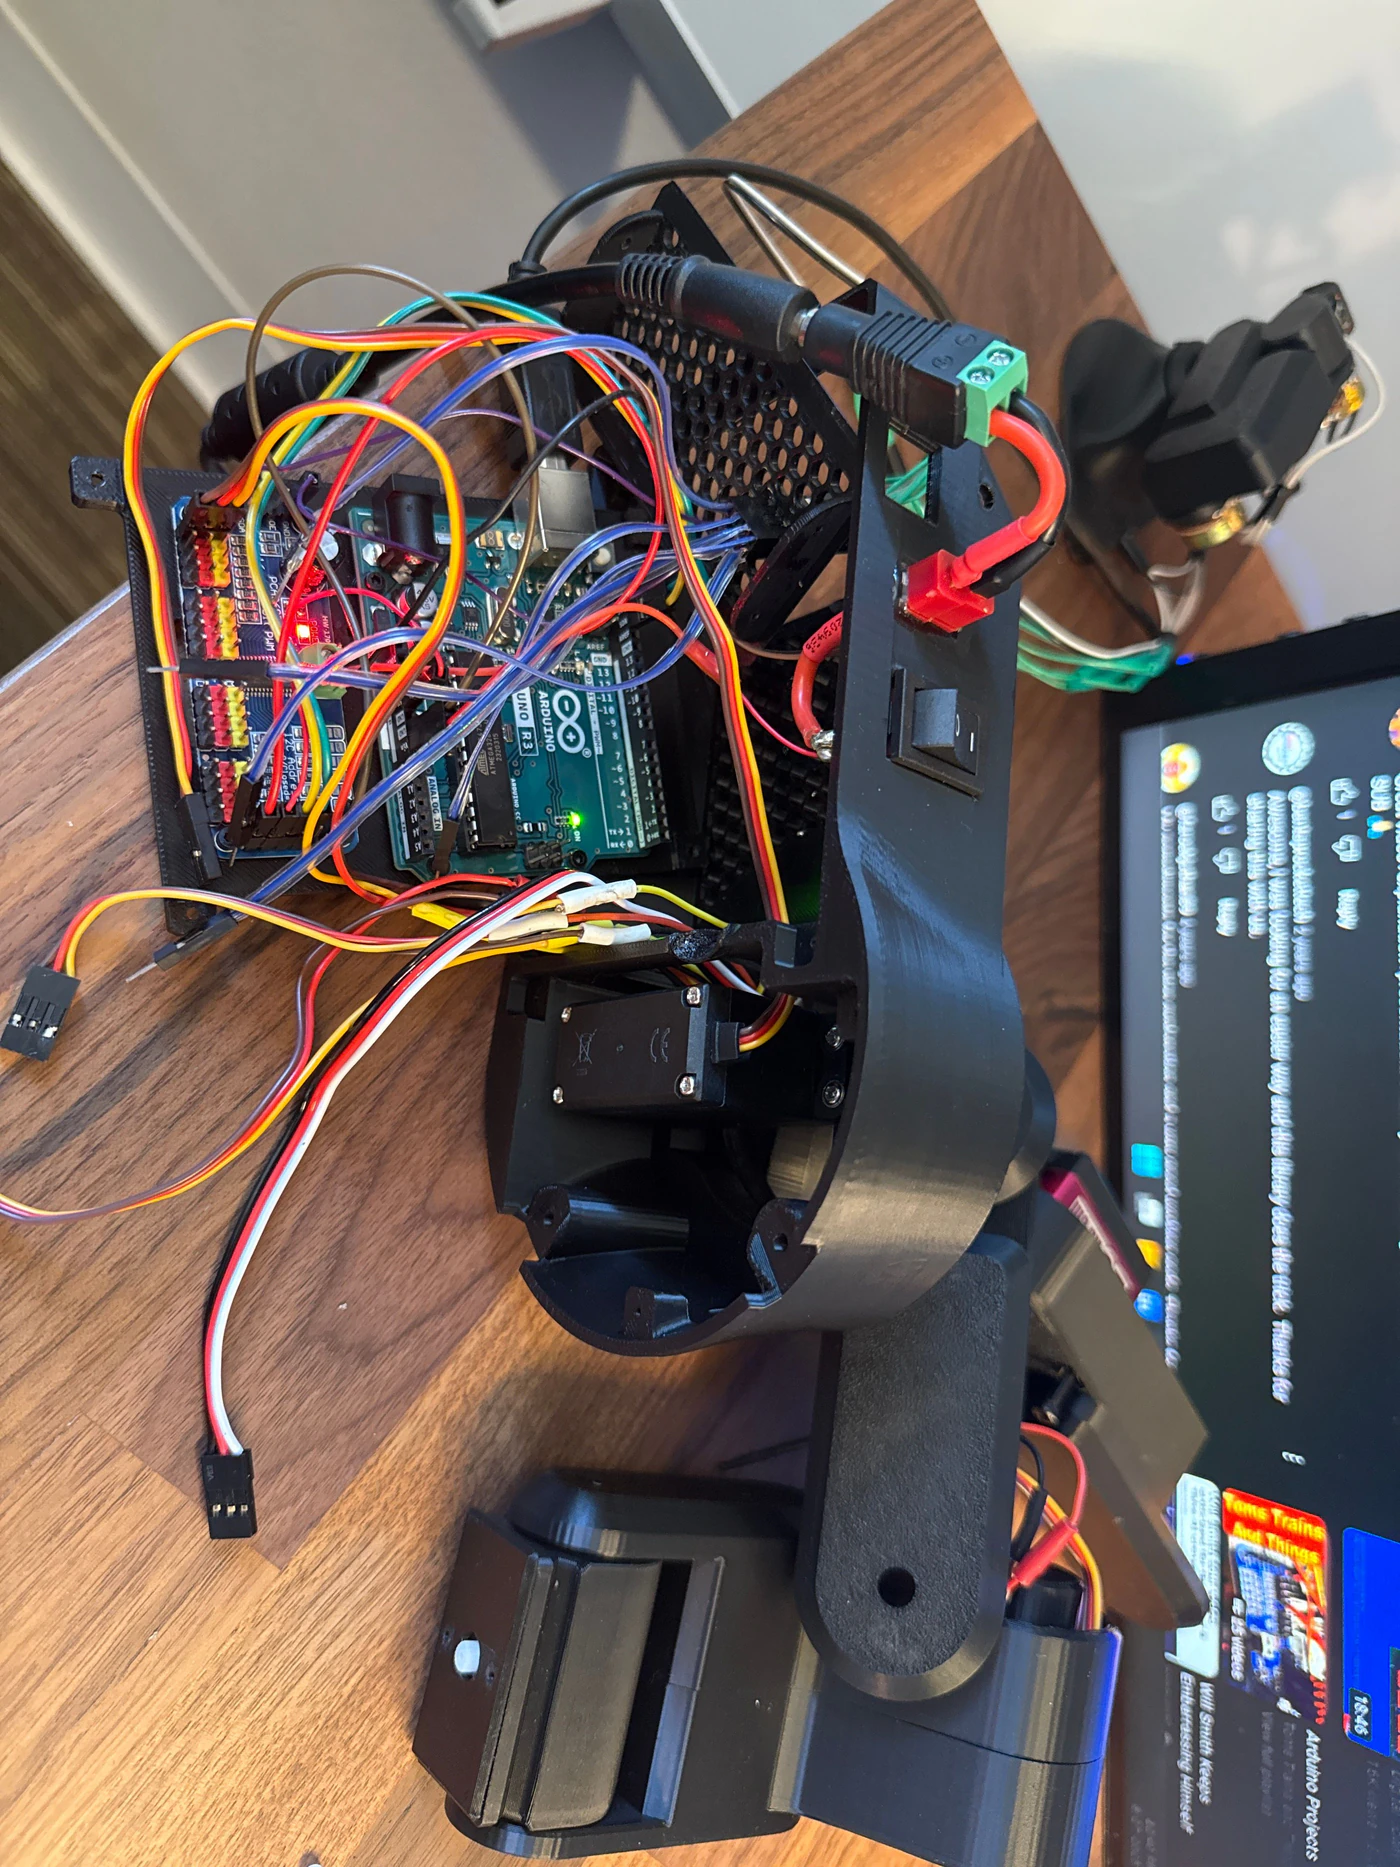
Real-time mirrored control through potentiometers and a servo driver.
My first big project going into fall semester. It taught me a lot about servo systems, CAD, and fabrication.
Mirrored controlThe armJoint testWiring and control