No. 03ASME Student Design Competition 2025/262025 to Present
Autonomous Waste-Collection Robot
As project lead, I took a 60+ member team through a full design cycle, from field schematics to competition day, on a robot that collects, sorts, and disposes of waste in a mock city.
60+team members led
01
Clean up a mock city, autonomously
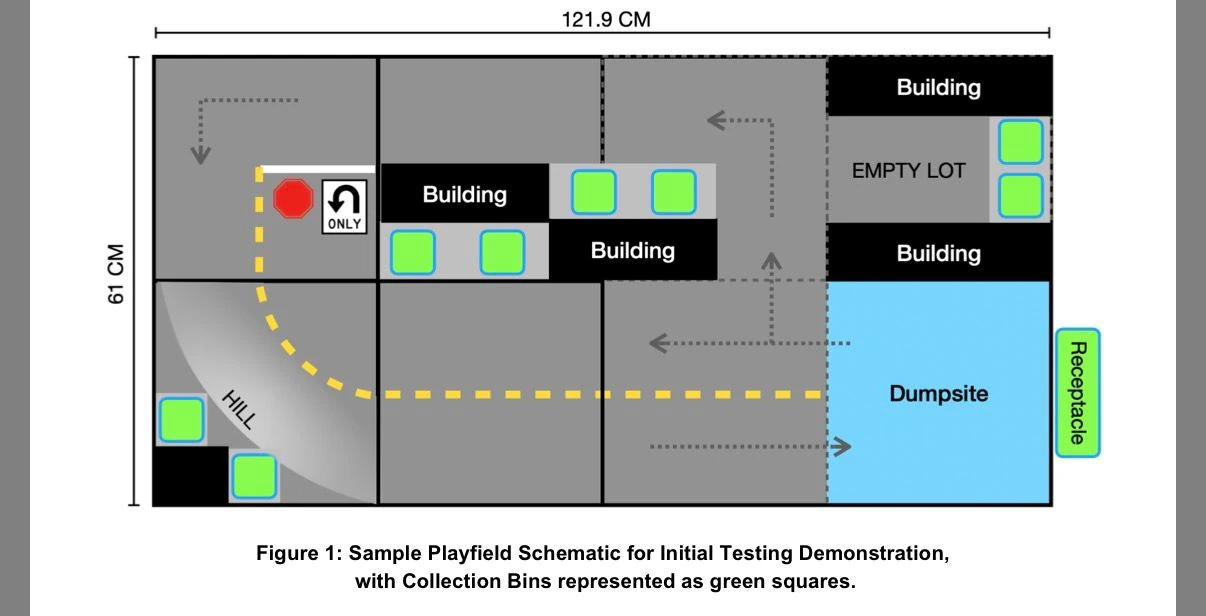
ASME’s 2025/26 Student Design Competition asked for a robot that could navigate a mock city playfield (streets, buildings, a hill), collect waste bins, sort them, and deliver them to a dumpsite, over inclines and rough terrain.
Sample playfield schematic from the competition rulesKickoff meeting
1 / 2
02
From omni-wheel CAD to a driving prototype
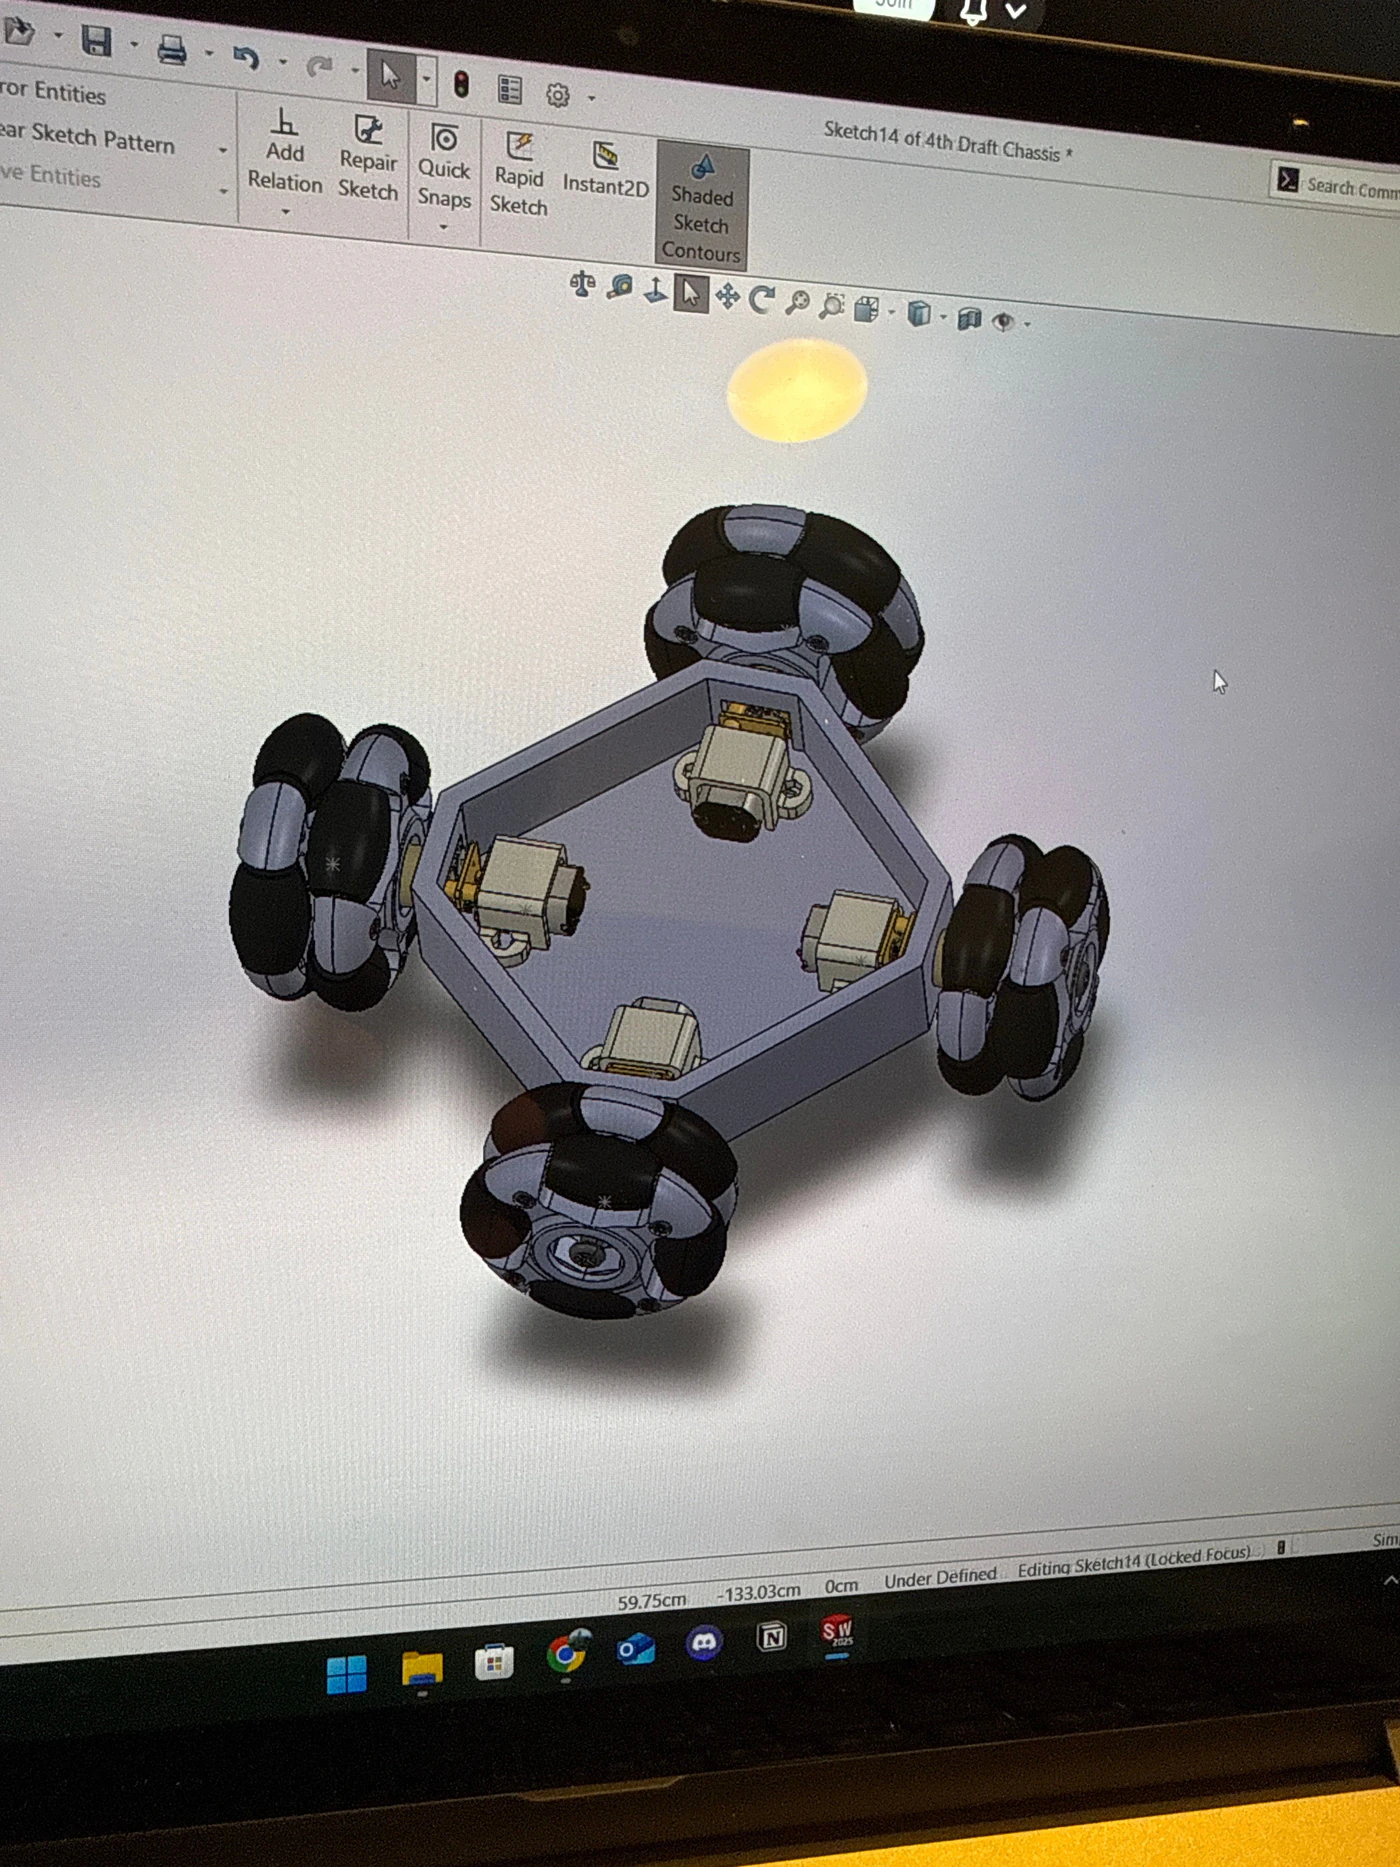
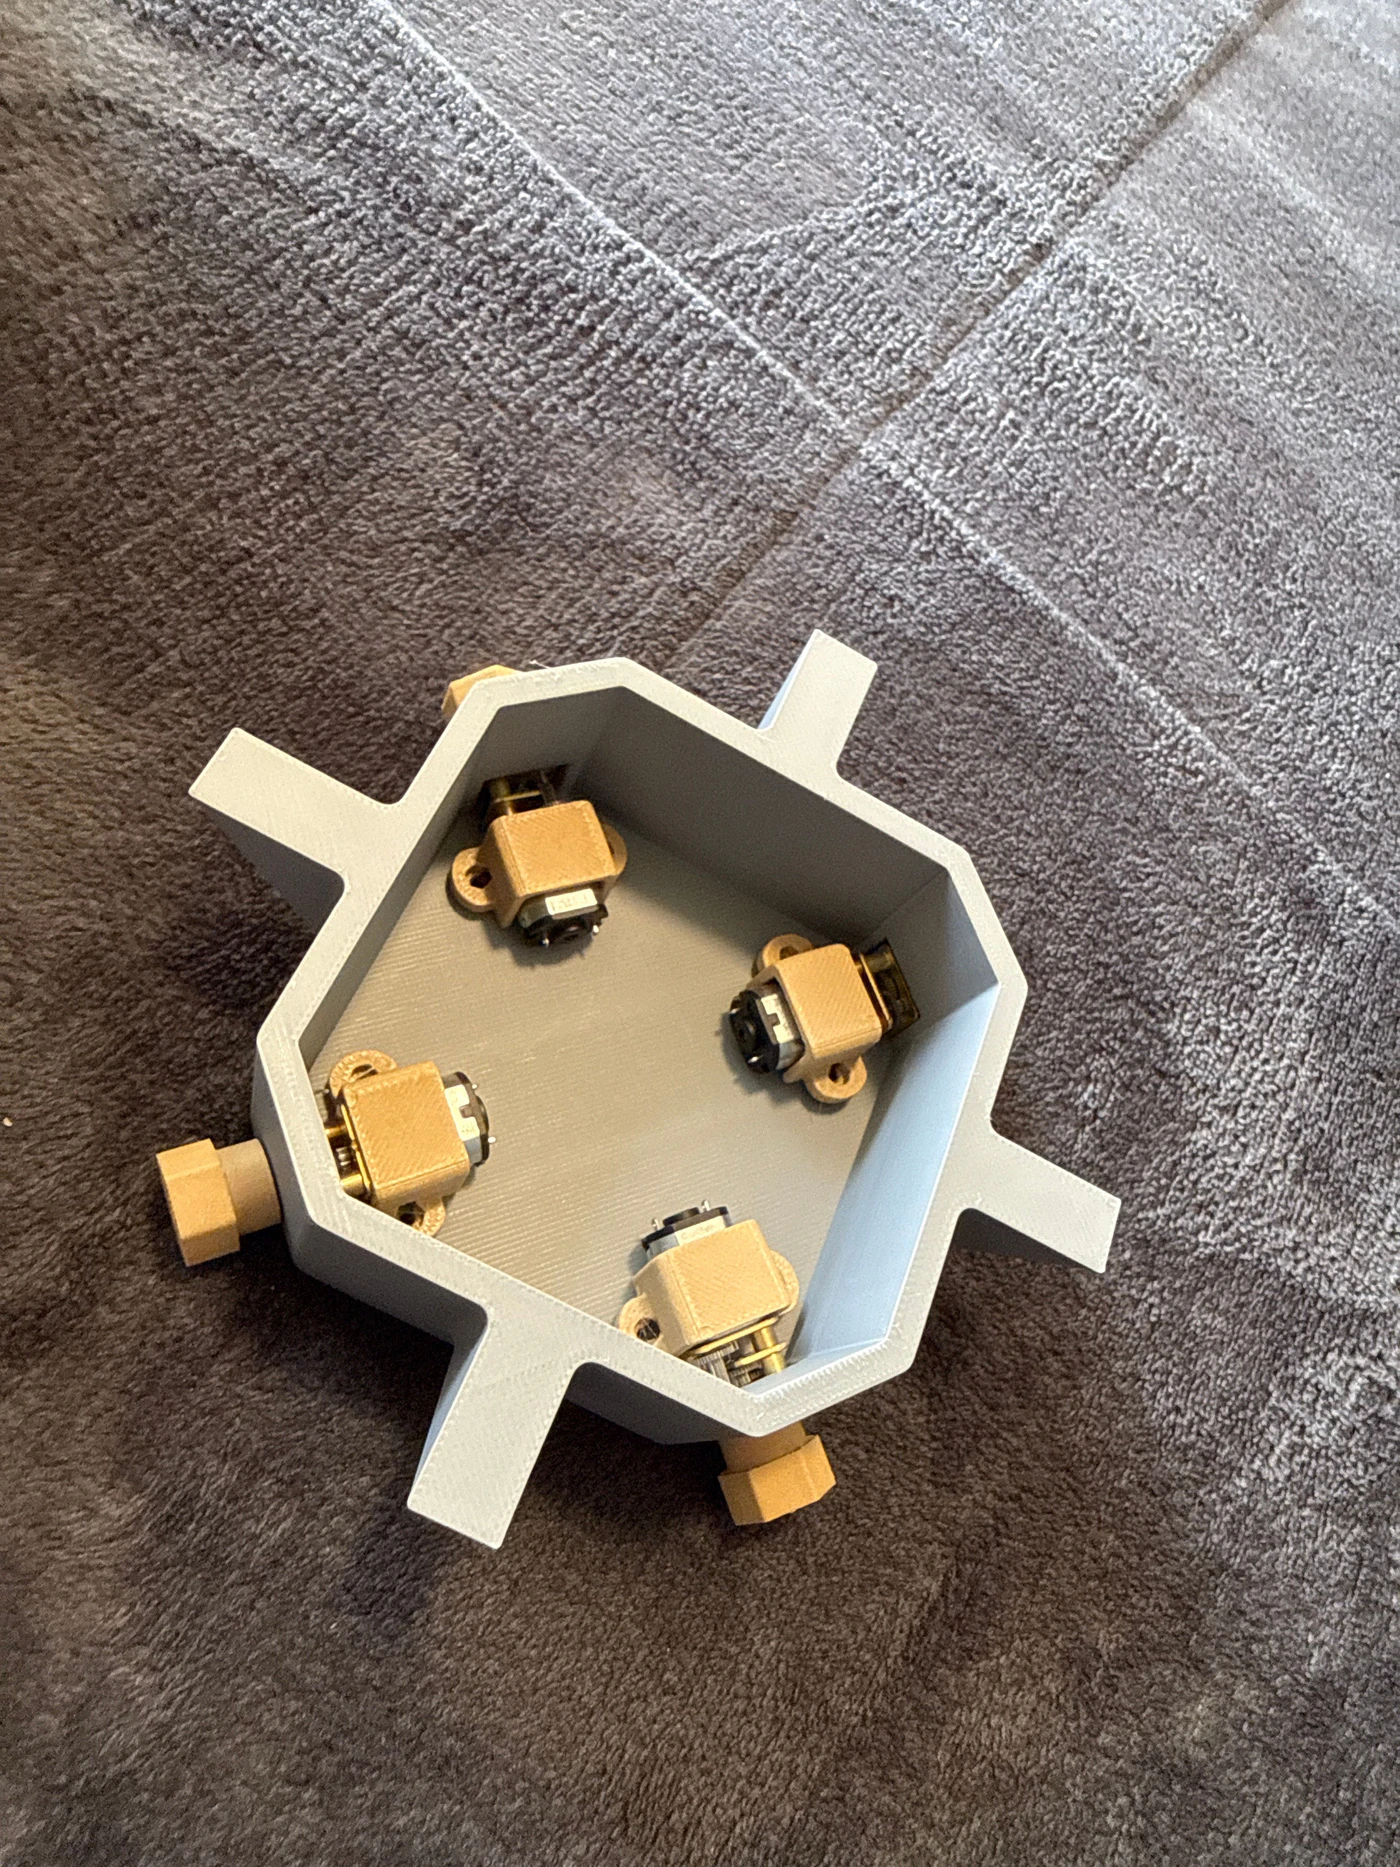
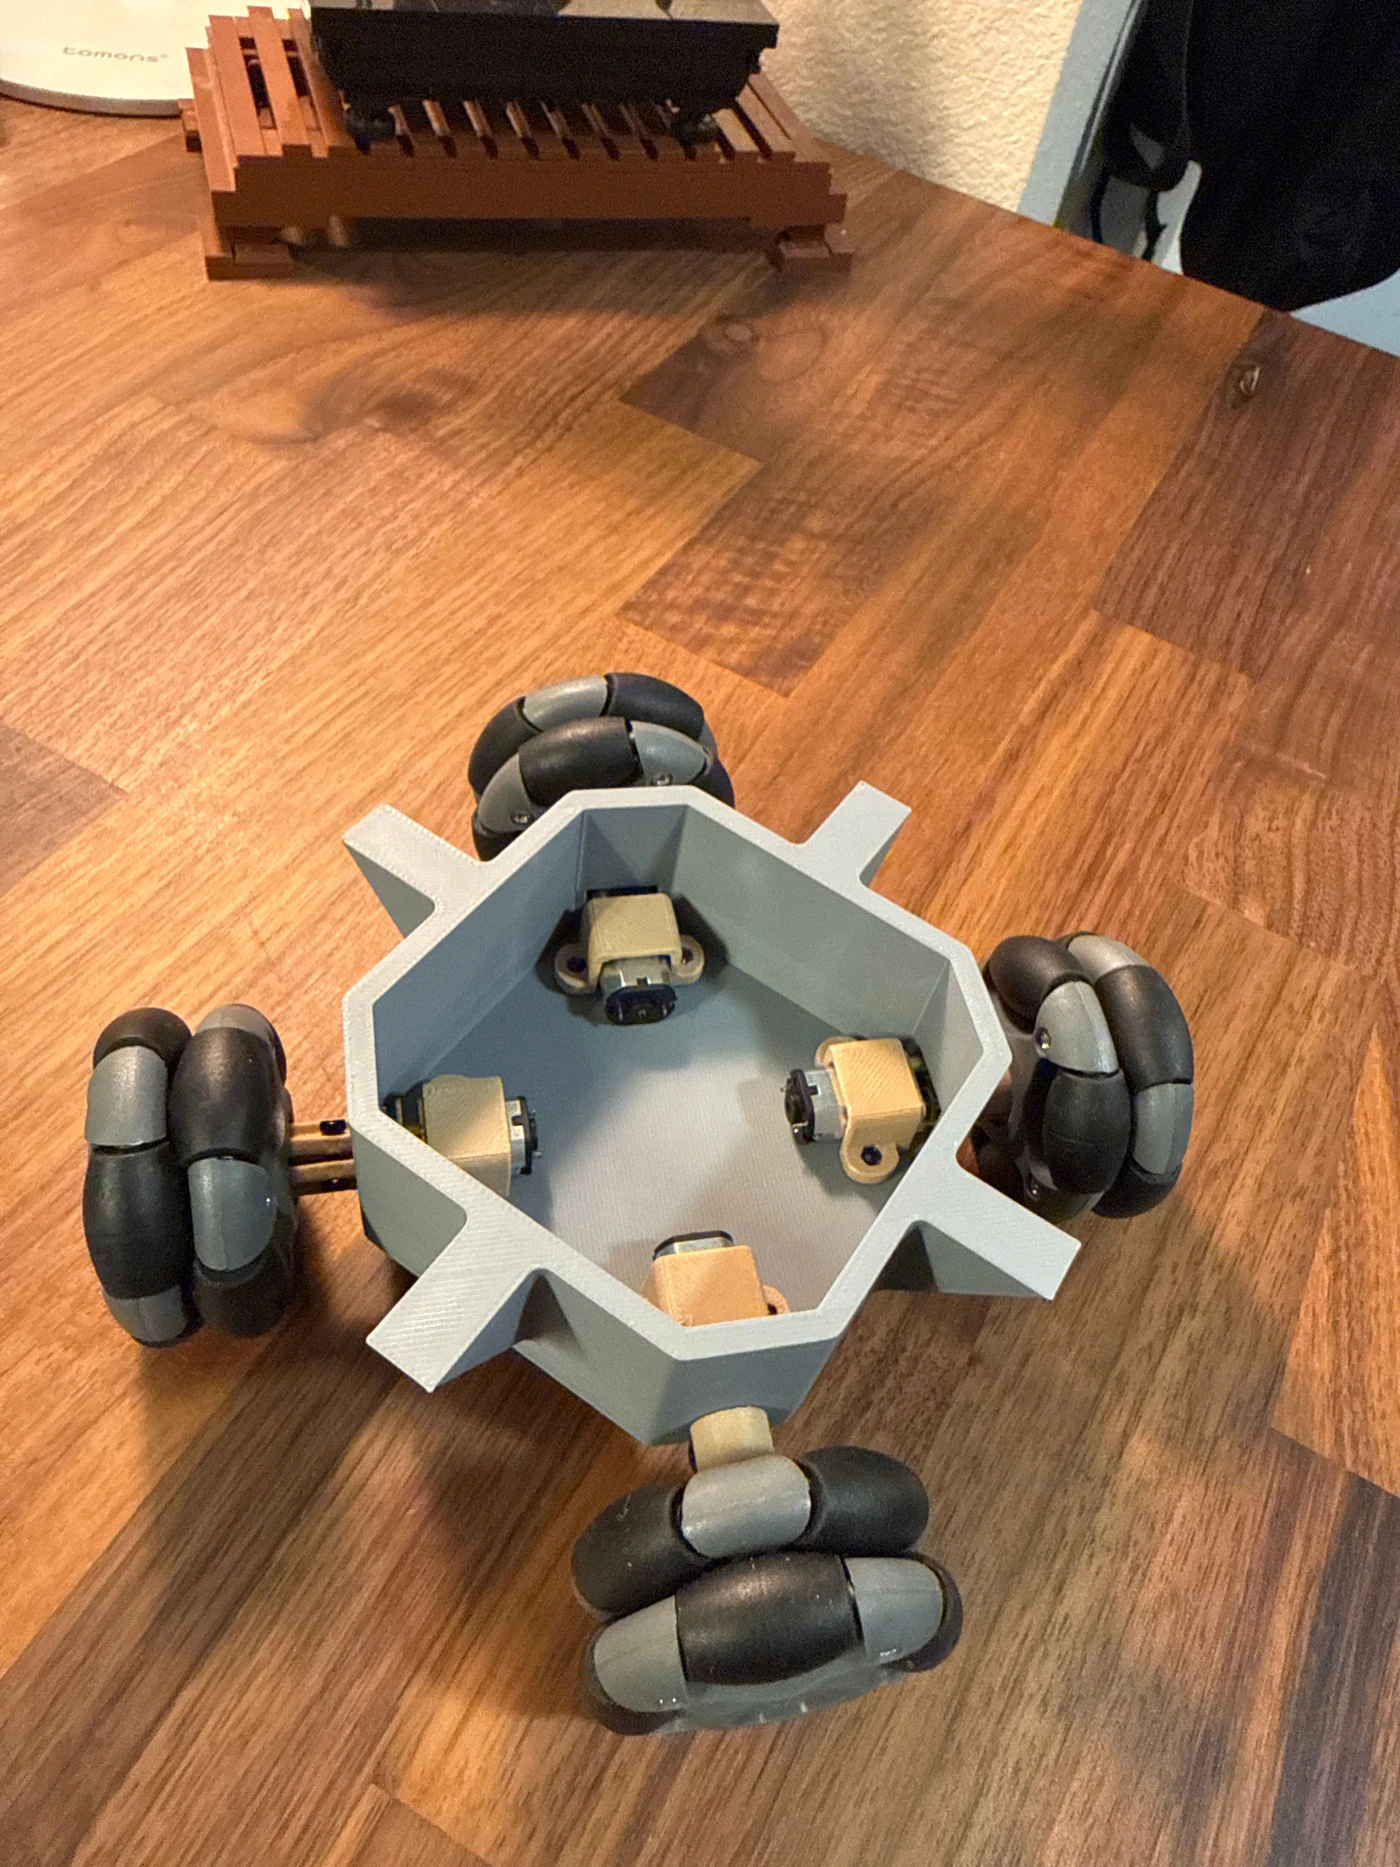
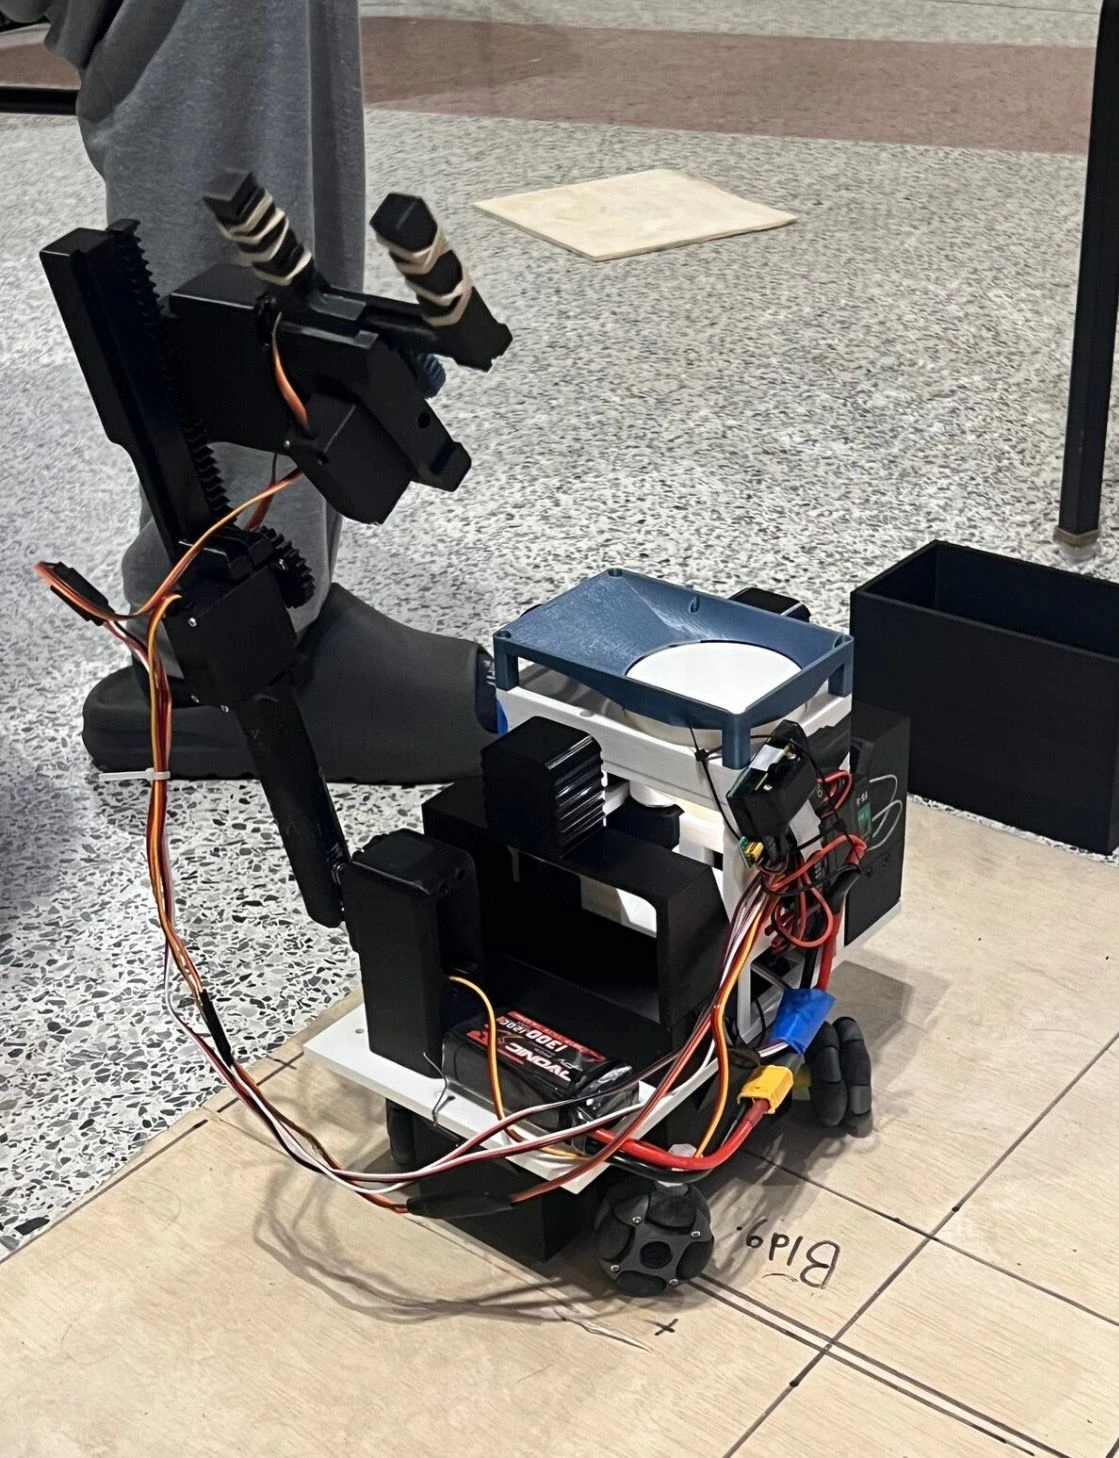
Hexagonal omni-wheel chassis designed in SolidWorks, then 3D printed and iterated.
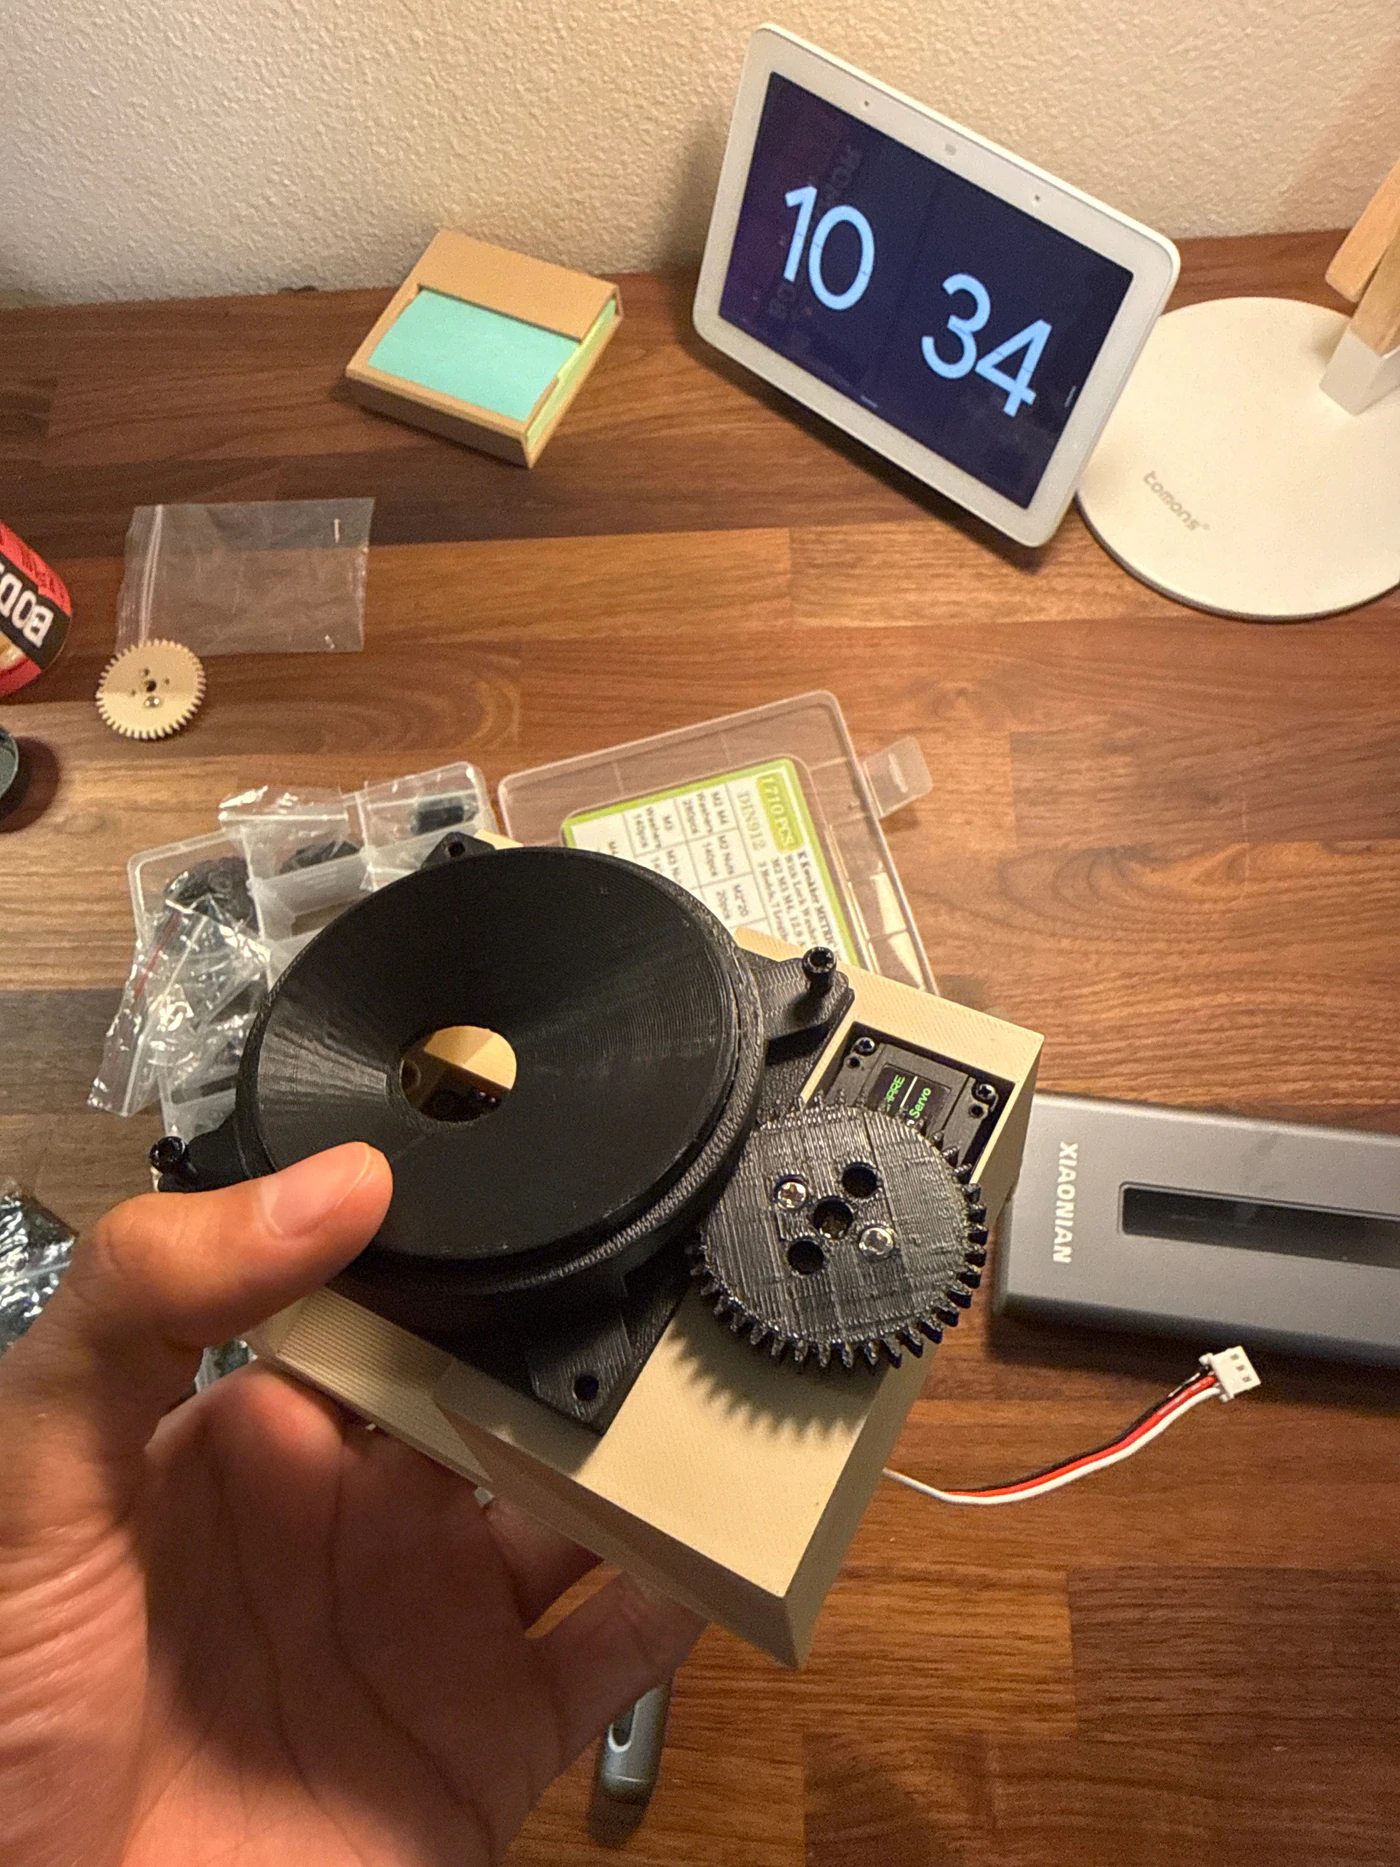
Gearbox and sorting mechanisms prototyped and tested on the bench.
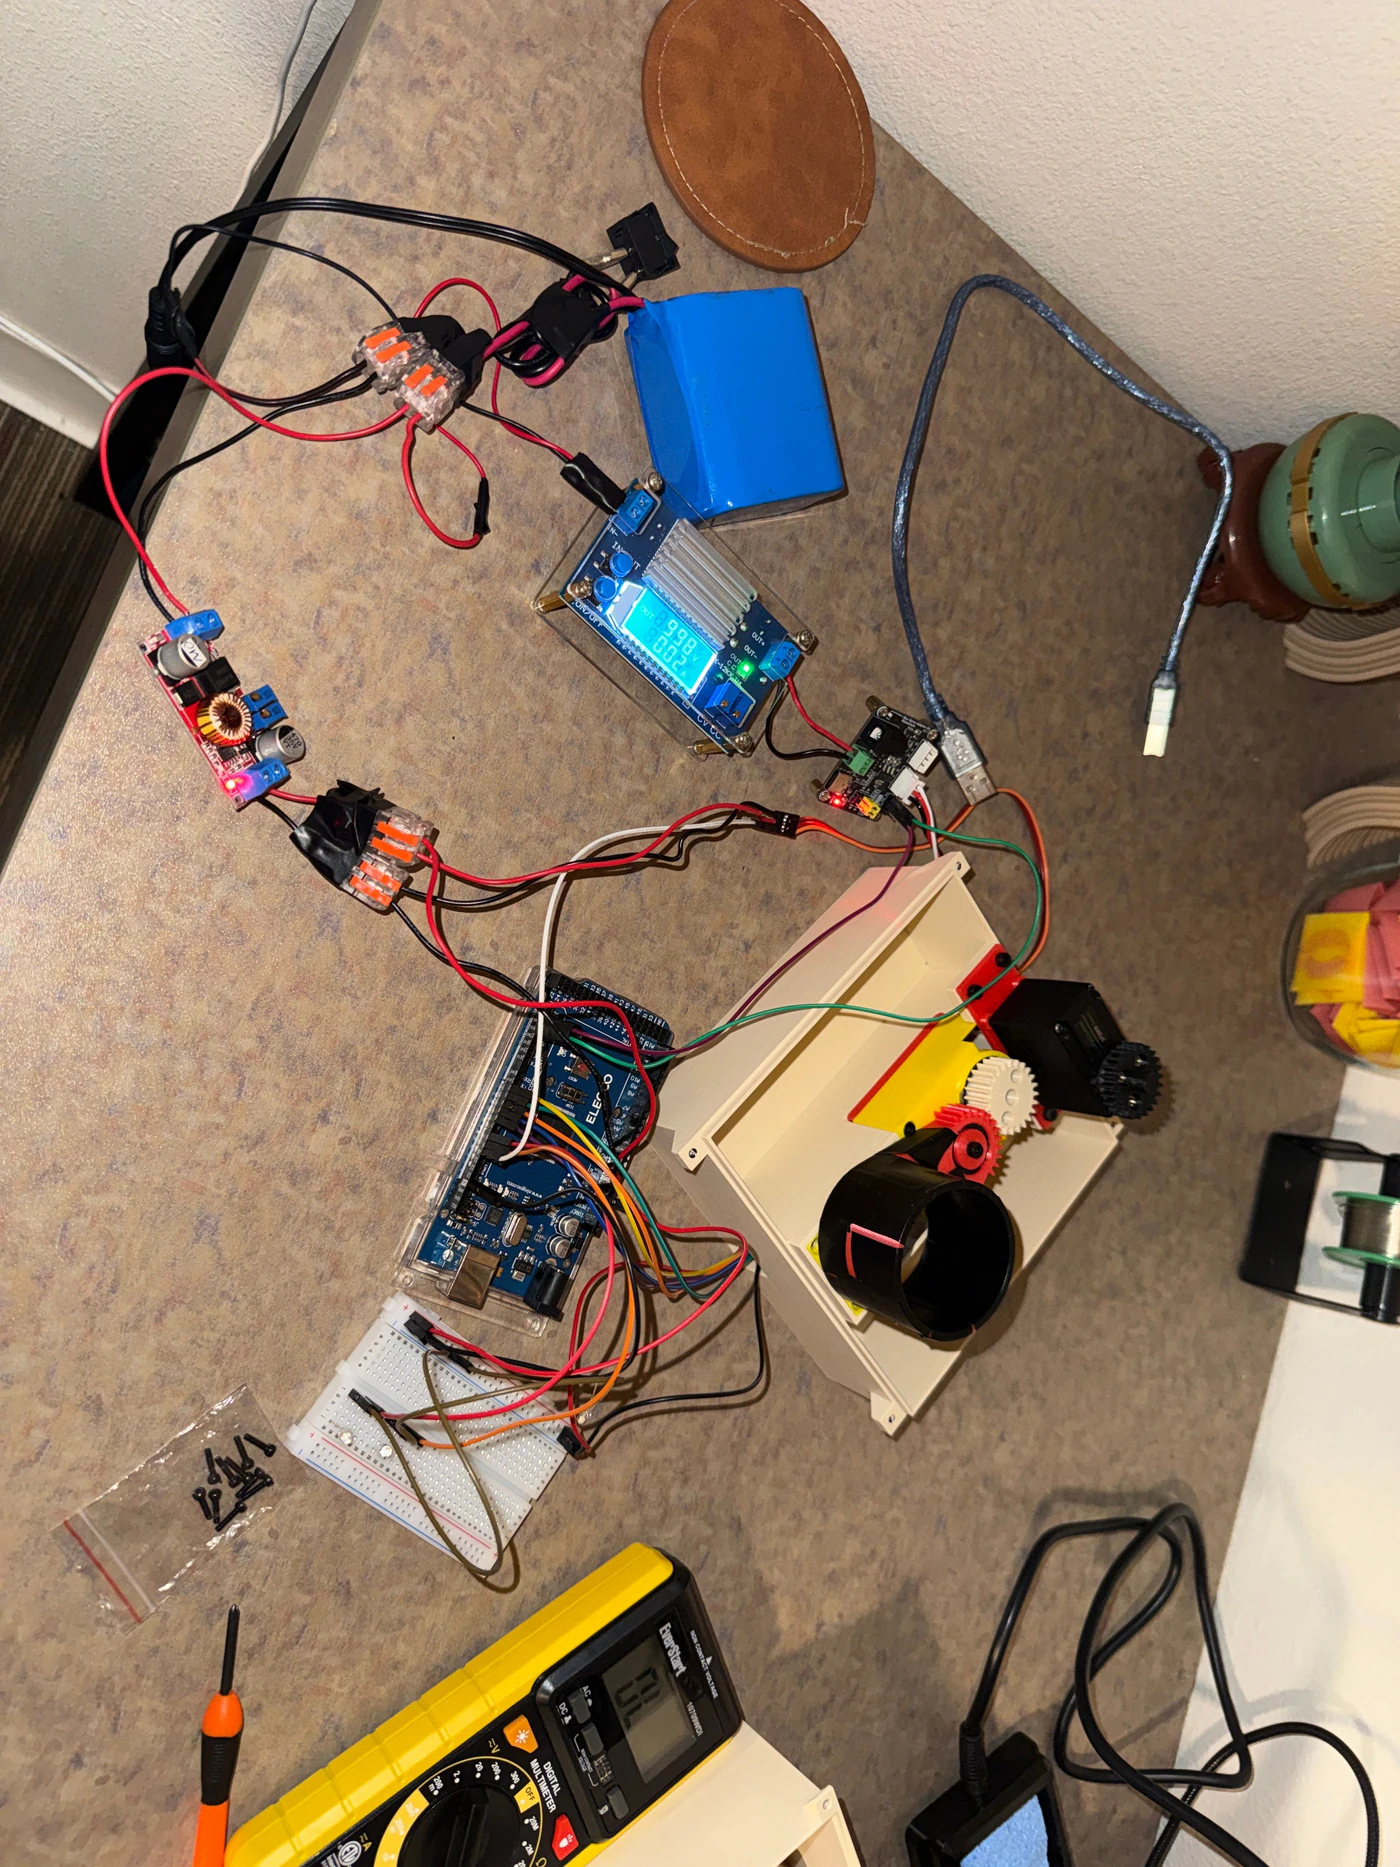
Electronics integration and drive testing on real surfaces.
Chassis CADFirst printed chassisChassis with omni wheelsEarly drive testGearbox prototypeSorting mechanism testElectronics bring-up
1 / 7
03
Keeping a big team building the same robot
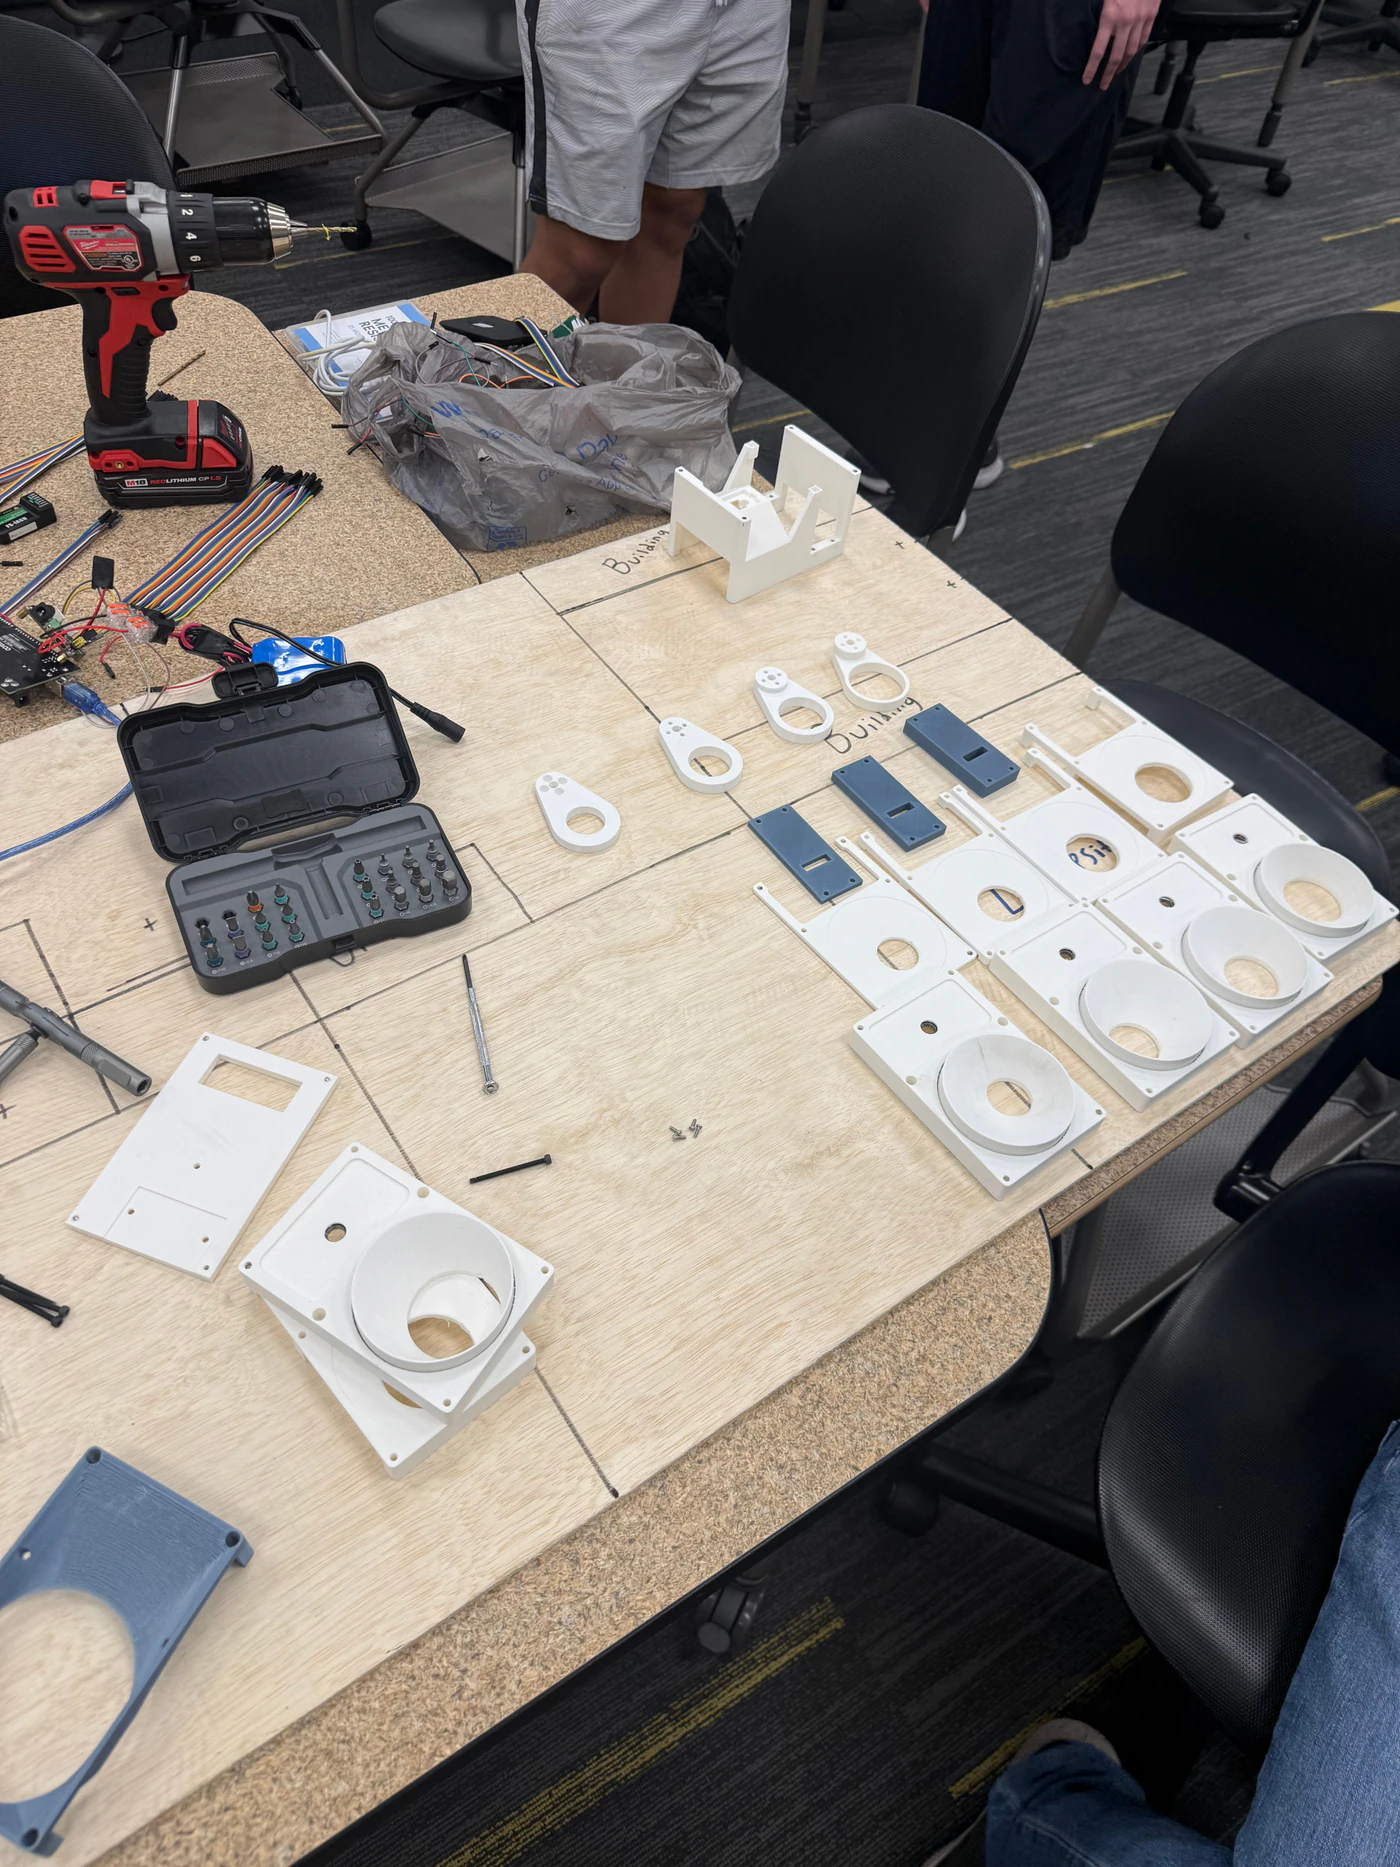
Coordinated CAD, prototyping, and testing across sub-teams for the full academic year.
Owned design validation: fabrication documentation, demonstration videos, and rule compliance to maximize scoring.
Build sessionDrive testCompetition robotCompetition day